🌈 Hi, there!
-
I am currently pursuing a Ph.D. degree at The Chinese University of Hong Kong, Shenzhen under the supervision of Prof. Junjie Hu. I received my Master’s degree in Control Science and Engineering from Shandong University in 2023, where I worked with Professor Yong Song.
-
My research interests focus on reinforcement learning and multi-robot systems. Currently, i am particularly interested in effective cooperation of heterogeneous multi-robot systems in complex scenarios.
🔥 News
- 2026.07: 🎉 One paper is acaccepted by IEEE Transactions on Systems, Man, and Cybernetics: Systems.
- 2025.11: 🎉 One paper is acaccepted by IEEE Robotics and Automation Letters.
- 2025.10: 🎉 National Scholarship at Shandong University.
- 2025.08: 🎉 One paper is acaccepted by Engineering Applications of Artificial Intelligence.
- 2025.07: 🎉 One paper is acaccepted by IEEE Transactions on Industrial Informatics.
📝 Publications
- An Intention-Guided Reinforcement Learning Approach with Dirichlet Energy Constraint for Heterogeneous Multi-Robot Cooperation, Heteng Zhang, Yunjie Jia, Zihao Sun, Yong Song, Bao Pang, Xianfeng Yuan, Rui Song, Simon X. Yang, IEEE Robotics and Automation Letters
- An Adaptive Reinforcement Learning Approach with Trait-Awareness for Heterogeneous Multi-Robot Cooperative Pursuit, Heteng Zhang, Yunjie Jia, Yong Song, Bao Pang, Xianfeng Yuan, Rui Song, Simon X. Yang, Engineering Applications of Artificial Intelligence
- Empowering Multi-Robot Flocking in Complex Environments via Effective Communication: A Deep Reinforcement Learning Approach, Yunjie Jia, Yong Song, Jiyu Cheng, Heteng Zhang, Wei Zhang, Rui Song, Simon X. Yang and Sam Kwong, IEEE TRANSACTIONS ON INDUSTRIAL INFORMATICS
🤖 Research
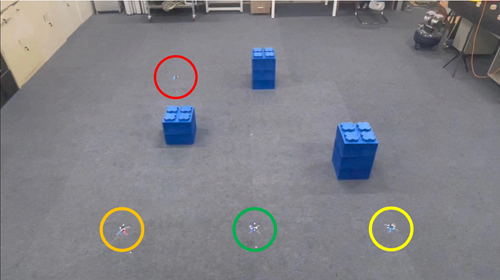
Collaborative Control and Evolution of Multi-Service Robots Based on Swarm Intelligence
Heteng Zhang, Yunjie Jia, Di Feng, Yuxuan Cui
-
This project involves developing a system to enable multi-robot collaboration, constructing and deploying the physical mobile robot platform.
-
We propose a reinforcement learning method to achieve efficient coordination of multiple robots.
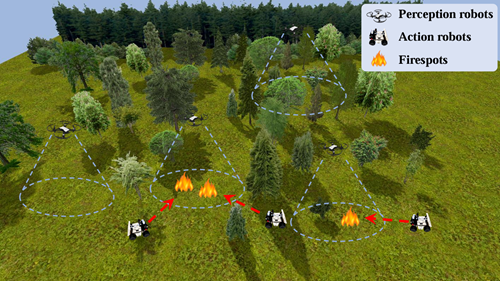
Cooperation of heterogeneous multi-robot systems in search-and-rescue scenarios
Heteng Zhang, Yuxuan Cui,Di Feng
-
A novel intention-guided reinforcement learning approach is proposed to facilitate the learning of far-sighted strategies and enhances adaptability in non-stationary environments.
-
We deploy the trained policies on physical mobile robot platform.
🏆 Honors and Awards
- 2025.10 National Scholarship.
- 2023.10 First Prize in China Robotics Competition and RoboCup China Regional Competition (5th Place Nationwide).
- 2023.04 Second Prize in RoboMaster Mech Master University League Competition.
- 2023.04 Second Prize in China University Intelligent Robot Creative Competition.
- 2021.12 First-Class Scholarship from the Hong Kong Sangma Foundation (Top 1%).
- 2021.12 Second Prize in TI Cup National Undergraduate Electronic Design Competition.
- 2021.11 Champion of Intelligent Robot Creative Competition in Zhejiang Province.
- 2021.08 Second Prize in RoboMaster Mech Master University Individual Competition.
- 2020.12 Zhejiang Provincial Government Scholarship (Top 5%).
- 2020.12 First Prize in Intelligent Robot Creative Competition in Zhejiang Province.
📖 Educations
- 2023.09 - 2026.06, Master, Shandong University, China.
Major: Control Science and Engineering GPA: 3.90 / 4
- 2019.09 - 2023.06, Bachelor, Zhejiang Sci-Tech University, China.
Major: Automation GPA: 3.75 / 4 (Top 3%)
💻 Internships
- 2025.06 - 2025.09, Momenta
 , Shanghai.
- 2024.07 - 2024.10, DJI
 , Shenzhen.
- 2023.06 - 2023.07, XPeng Motors
 , Shenzhen.